Integrated joint module
Motor, transmission, and servo functions are packaged as a compact building block for articulated mechanisms.
Robot Joint Actuators / 24 V / 48 V, 46 Nm Configuration
An integrated smart servo joint for robotic arms, automation equipment, humanoid development, and other articulated robot systems.
Product overview
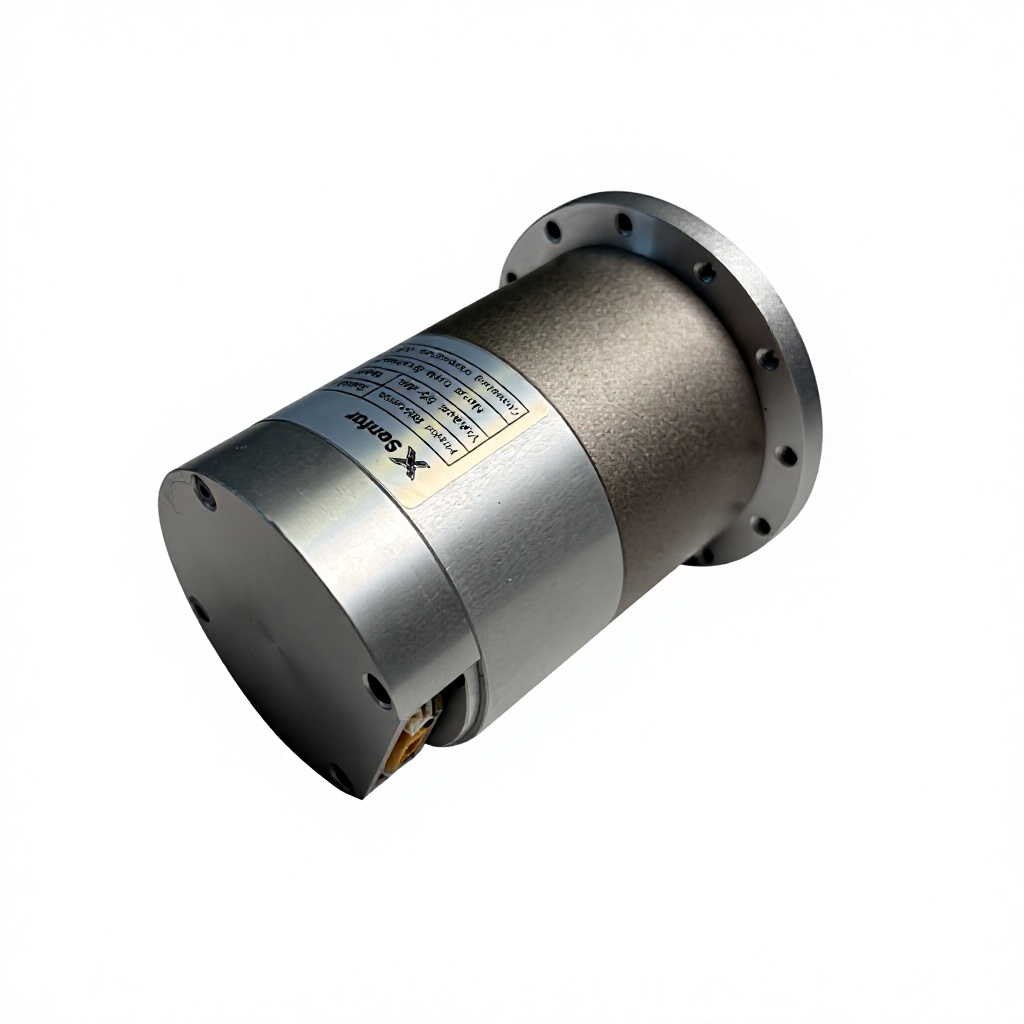
This joint actuator combines motor, reduction, sensing, and servo-control functions in a compact articulated module. It is intended for teams building robotic arms and other multi-axis mechanisms. Output speed, peak torque, precision, communication protocol, thermal limits, and mechanical interfaces must be reviewed against the selected actuator model.
Motor, transmission, and servo functions are packaged as a compact building block for articulated mechanisms.
The published configuration is offered for 24 V and 48 V system architectures.
Actuator selection can be matched to joint torque, speed, packaging, precision, and control requirements.
Technical specification
Engineering support
Request protocols, drawings, SDK information, or configuration guidance through the engineering team.
Request Technical FilesStart a project conversation
Share the payload, terrain, dimensions, quantity, and control requirements of your project.