Omnidirectional mobility
The wheel arrangement supports multi-directional maneuvering where route geometry and floor space are constrained.
Wheeled Robot Chassis / 100 kg / 48 V Configuration
An omnidirectional mobile base with four-wheel independent suspension for payload integration, autonomous navigation, and service-robot development.
Product overview
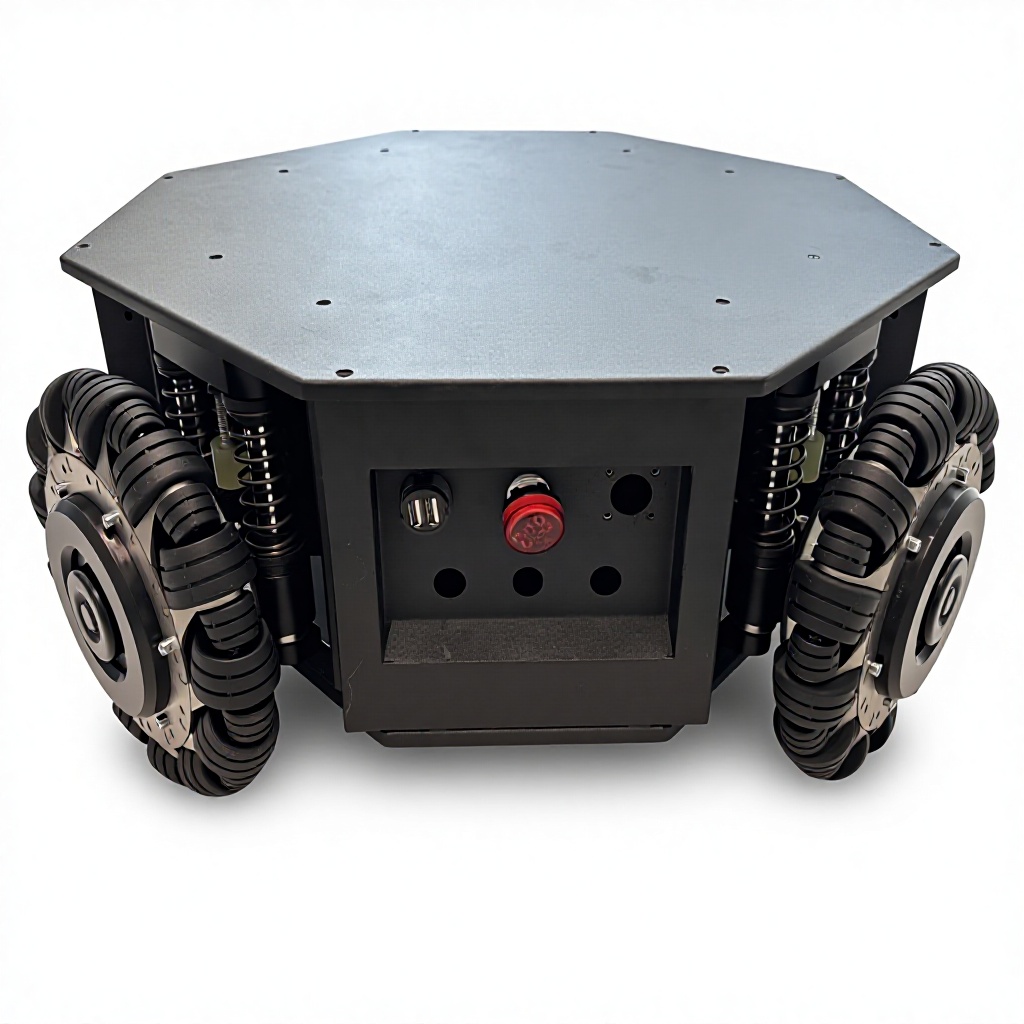
This published configuration combines omnidirectional wheel motion with independent suspension and a flat payload deck. It provides a practical mobility foundation for teams integrating perception, compute, autonomy, and task-specific equipment. Final dimensions, interfaces, runtime, and environmental limits must be confirmed for the selected project configuration.
The wheel arrangement supports multi-directional maneuvering where route geometry and floor space are constrained.
Four-wheel suspension helps maintain wheel contact and provides a mechanical base for indoor mobile-robot development.
The upper structure provides mounting space for customer payloads, sensors, compute, and application equipment.
Technical specification
Engineering support
Request protocols, drawings, SDK information, or configuration guidance through the engineering team.
Request Technical FilesStart a project conversation
Share the payload, terrain, dimensions, quantity, and control requirements of your project.